









fischertechnik

ROBOTICS STEM Coding Pro
Learn programming hands-on in primary school
Practice Scratch programming and learn how to operate the user-friendly controller
Understand the way actuators and sensors work

Robotics Add-On: AI
Explore the future technology!
Combined with the STEM Coding Ultimate AI Set (required), this set allows you to build 3 AI focused models.
- Understand fundamentals of working with AI and machine learning
- Perform basic object detection
- Learn how to measure and evaluate model and classifier accuracy
- Experience the importance of high-quality training data for machine learning
- Discover how AI is used in real-life contexts
Components: 314
Experiments: 6

Robotics Add-On: Industrial Robots
Two realistic six-axis robot models that you can assemble and program yourself
- The set enables learners to deal intensively with industrial robotics and to prepare practically for the requirements of the modern professional world
- Two realistic six-axis robot models
- The hands-on experience allows you to not only gain theoretical knowledge, but also develop practical skills
- Important: Requires STEM Coding Ultimate AI set to build all models and perform all functions.
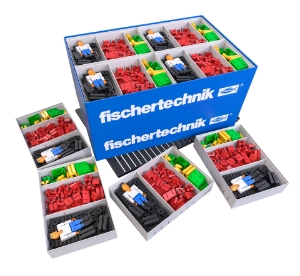
CLASS SET Basics
Foster creativity with the class set for elementary school
- Included building ideas allow an easy introduction to first constructions
- Building ideas for inspiration
- Creative building
- Colourful building blocks and figure for role play
- Encourage creativity and hand-to-eye coordination
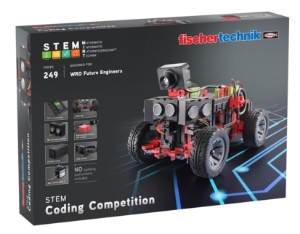
STEM Coding Competition
The all-in-one set for successful robotic competition participation
- Specially developed for competitions
- TXT 4.0 Controller included
- Recharegable battery pack and charging unit
- Kit for individual chassis
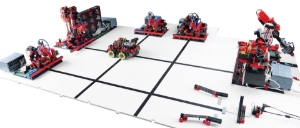
Agile Production Simulation 24V
The fischertechnik Agile Production Simulation 24V with S7-1200 PLCs is designed as an ideal training model tailored for Higher Education and professional Industrial training applications. Consists of individual modules such as incoming and outgoing goods, high-bay warehouse, milling station, drilling station, and quality assurance with AI. A driverless transport system flexibly transports workpieces between the individual stations and ensures a flexible production process that can be adapted to customer requirements.
Download Brochure here
Storage and Transport Case for Agile Production Simulation
The storage and transport case for fischertechnik Agile Production Simulation set.

Maker Kit Car
The perfect car chassis as a basic model
Top Features
- Robust car chassis
- The supplied 3D data for common developer boards makes it easy to integrate additional components.
- Simple expansion options
- Includes an encoder motor, a differential gear and a steering knuckle with servo motor for unrivalled possibilities.
- Includes 119 parts for building one model.
- Recommended for age 14 and above.

Maker Kit Omniwheels
Discover the fascination of movement in every direction with our basic model of a driving robot!
Top Features
- The Omniwheels enable unique locomotion.
- Simple expansion options.
- The 3D data supplied for common developer boards makes it easy to integrate additional components.
- Includes 4 encoder motors, 4 Omniwheels, steel axles and gears in front of each Omniwheel for maximum flexibility.
- Includes 201 parts for building one model.
- Recommended for age 14 and above.
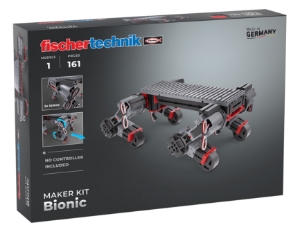
Maker Kit Bionic
Create your own walking robot with our flexible base!
Top Features
- The Maker Kit Bionic enables you to create your own walking robot with a flexible basis.
- The supplied 3D data for common developer boards makes it easy to integrate additional components.
- Simple expansion options.
- Included are 8 servo motors with fischertechnik mounts and a walking robot chassis with a flat platform for your own superstructures.
- Includes 161 parts for building one model.
- Recommended for age 14 and above.
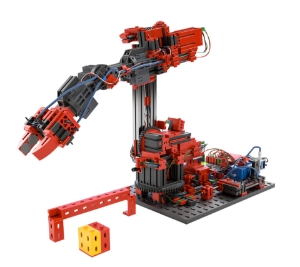
6-Axis Robot 9V
- Coding of a multi-axis robot
- Can be equipped with both a vacuum suction cup and a gripper
- Position determination via 6 axes
- Three of the six axes are controlled with encoder motors, three others with digital servos
- Programming can be done either via Python or ROBO Pro Coding
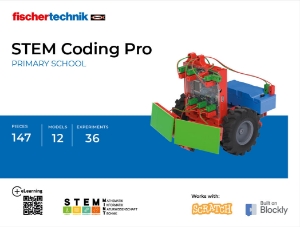
STEM Coding Pro (No Battery)
Learn hands-on programming, computer science, and robotics fundamentals in primary school with Robotics STEM Coding Pro.

STEM Coding Max
Hands-on and problem-based construction and programming in secondary school
- Explore and perform everyday tasks in Information Technology and Robotics
- Learning block-and text-based programming for an easy-to-use controller
- 11+4 models
- 42+ Hours of Learning
- 2-4 students
- Requires 9v battery—not included
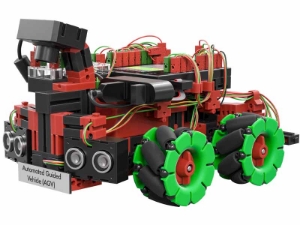
APS ADD ON: Automated Guided Vehicle
Ideal add-on for expanding the capabilities of the Agile Production Simualtion Model
The APS Add On: Automated guided vehicle system extends the Agile Production Simulation (APS) with an additional automated guided vehicle system (AGV). This is responsible for intralogistics within APS and enables agile and flexible processes. The additional AGV significantly increases the possibilities of intralogistics. Parallelization and prioritization in the production workflow can be planned, tested and experienced. At the same time, the complexity of logistics processes increases.
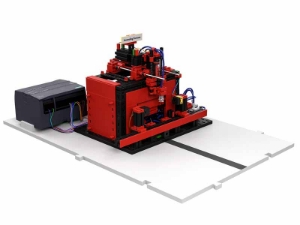
APS ADD ON: Annealing Furnace 24v incl. PLC S7-1200
Expansion module for use with the Agile Production Simulation model.
The APS Add On: Kiln adds a new production module to the Agile Production Simulation (APS). The standard configuration with a drilling and milling module is extended by the option of a kiln. The additional process module allows the introduction of new derivatives into production or the expansion of existing production configurations by an additional process step.
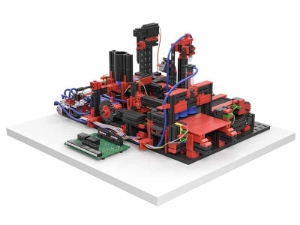
Production Line 24v
The fischertechnik production line 24V simulates a series of interlinked production steps.
At the beginning, the workpieces are loaded from a magazine onto a rotary indexing table with four stations using a pneumatic pusher. The rotary indexing table transports the workpieces step by step to the drilling and welding station, where the workpieces are processed. At the last station of the rotary indexing table, a vacuum suction gripper removes the processed workpieces and places them on a conveyor belt. This transports the workpieces to the palletizing unit, where 3 workpieces are collected and then pushed onto a pallet.